Battery Application Solutions for Industrial Robotic Arms
Battery Application Solutions for Industrial Robotic Arms
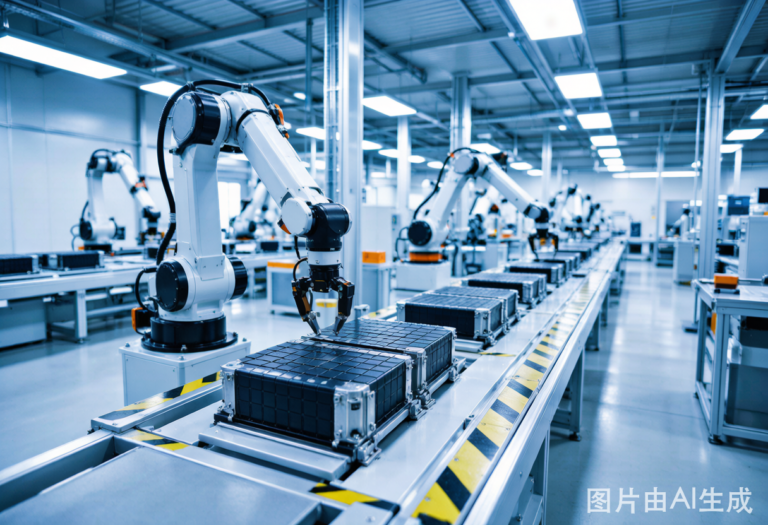
Factory floor robots were always tethered: a cable track, a slack loop, eventually wear, jam and unplanned stoppage. Tetherless designs — arms that run on an onboard pack, dock at a charge station between cycles, and hand off work at a fixed station — are now realistic for a growing share of cells. Battery application solutions built around lithium chemistries make that possible, and they also cover the fixed-side auxiliaries that keep a cell running: gripper tool power, rotary joint buffers, and safety-rated shutdown packs.
Why the Cable Has to Go
A cable on a moving link fails at the point of flex, usually 6–18 months into a shift cycle. Replacing a robot harness means the line down, a specialist, and a re taught teach-programme offset. Elimination of the moving cable removes that entire failure mode and lets the arm sweep a larger envelope without collision risk from a whipping harness. It also drops the energy wasted in dragging several kilograms of copper around at speed.
Where the Power Actually Goes
Most service arms draw a few hundred watts in hold and a few kilowatts in burst move, so the pack is sized for the worst motion segment rather than average draw. The energy that matters is per cycle: a payload-laden extension at full speed is the discharge peak, and the dwell at the far position is the heat soak. Size the pack to cover a full work cycle with 30% reserve, then confirm the voltage droop under that peak keeps the servo within its torque band.
Robotic Power Comparison
| Attribute | Lithium Pack (tetherless) | Cable Harness | Supercapacitor Buffer |
|---|---|---|---|
| Moving-mass penalty | Removes cable — net lighter | 2–6 kg per link | Negligible |
| Burst current | High, seconds | Unlimited from mains | Very high, sub-second |
| Energy per charge | Hours of duty | Unlimited | Seconds |
| Maintenance item | BMS, periodic balancing | Flexing cable — frequent | Minimal |
| Footprint need | Docking station required | — | Very small |
Integration Notes
Place the pack at the base or the fixed link wherever possible so it does not add inertia to the moving joints — rotating mass costs accuracy and cycle time. Take the DC bus to the joint drives through a soft-start inrush limiter, because a cold lithium pack presented to a servo bus produces a current spike that can trip the cell’s protection. Shielding matters too: robot controllers generate strong EMI, and an unshielded pack lead is an easy source of encoder errors.
Safety in a Shared Cell
Industrial cells demand the same discipline as any high-power lithium installation: certified cells, a BMS with per-cell supervision and load-path fusing, a rigid IP-rated housing with a keyed connector that cannot mate backwards, and thermal monitoring on the power electronics as well as the pack. Emergency stop must cut the pack contactor within milliseconds, not through the controller logic. Vent the enclosure to outside the robot envelope so a fault event cannot vent toward an operator.
People Also Ask
Will a fully wireless robot arm match cycle time? It matches or beats the cabled version once the cable inertia and flexing losses are counted; the usual adjustment is to re-tune the motion profile for the pack’s voltage droop at peak torque.
Do I still need a cable for safety shutdown? Yes. Keep the functional safety circuit hard-wired through the light curtain and e-stop; use the battery only for prime mover power, never for the safety path itself.
How long does a tetherless pack run per charge? Typically 1.5–6 hours of production, or 300–1500 weld/motion cycles, depending on payload and duty ratio; fast docks recover 80% in 5–12 minutes.
Written by Karl at China Battery Technology. Request a quote.